Projects

Automotive Telemetry Board

Rev2 Complete
PersonalPersonal

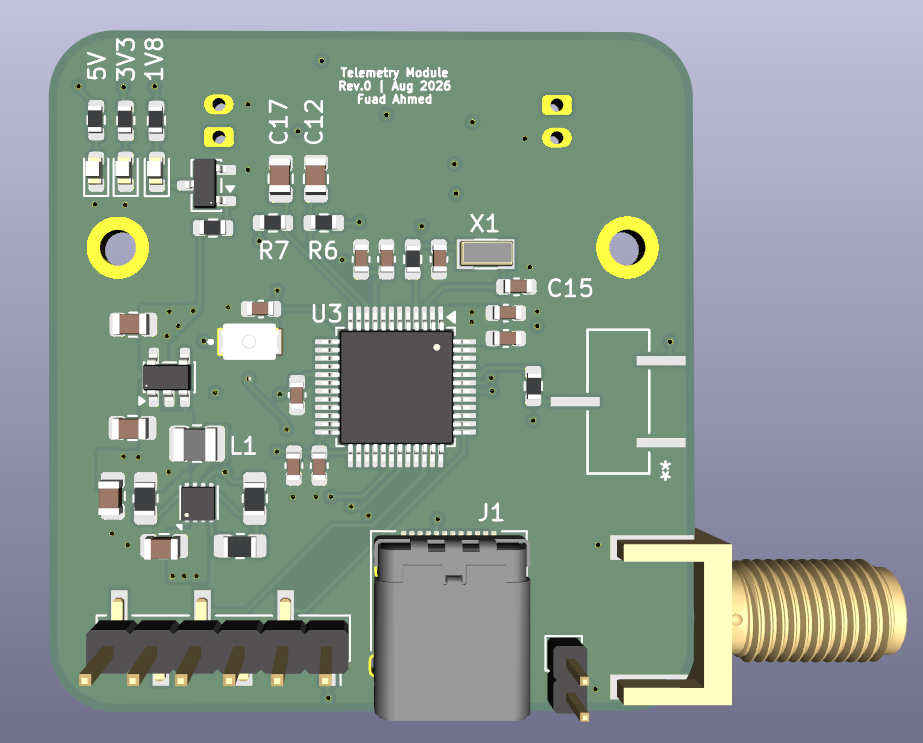
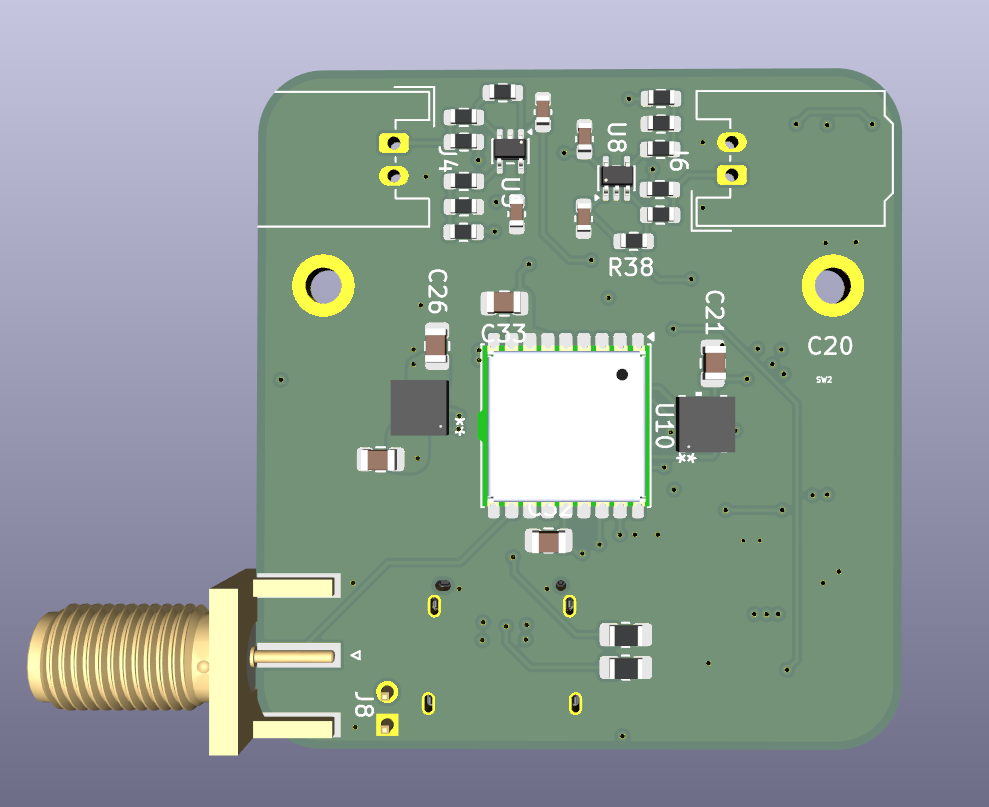
Automotive Telemetry board for data collection during testing. Logs vibration, pressure, acceleration and temperatures. Started this project to use while testing Paradigm and Formula MUN vehicles.

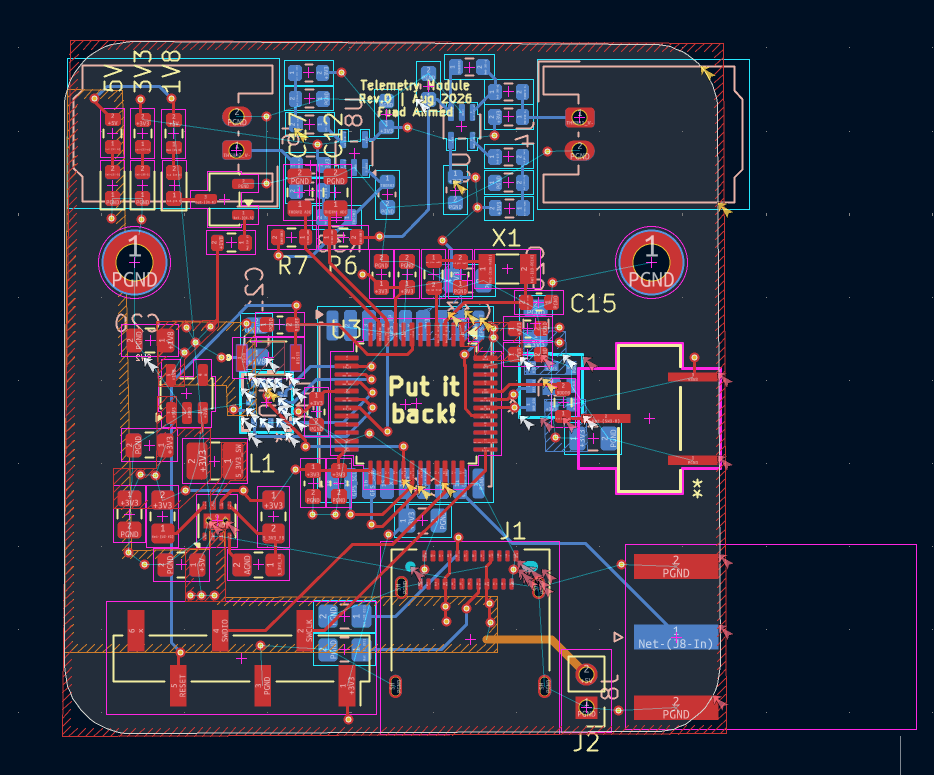
Targets were to have a PCB with an overall footprint below 50mm x 50mm, with mounting holes. Overall BOM price target was below $60 CAD. This was achieved through careful IC selection and reduction of unique parts.

  • Uses SPI and I2C to log data from onboard Pressure Sensor & Accelerometer
  • Logs position using U-Blox MAX M10-S over I2C. This was selected due to integrated LNA, SAW and low price
  • Powered over USB-C 5V. Intended to allow connectivity and testing from any PC, as well as be powered using common power banks
  • Onboard TI TPS62160DSG buck converter to convert 5V to 3V3
  • Onboard Diodes Inc. AP2112 LDO to convert 3V3 to 1v8 to power BMP585
  • Power indication LEDs for all power stages (using FET for 1V8 given 2V forward drop of LED)
  • Thermistor linearization circuit to allow for easy modification of temperature resolution for varied testing scenarios

Rev2 Modifications vs Rev1

  • Changed STM pin selection for simplified routing
  • Changed from standard 20 pin SWD header to 6 pin debug header to connect to NUCLEO-F446RE CN4
  • Switched from USB-PD only to USB 2.0
  • Added MicroSD card slot to log data over SPI from the STM, allowing for data to be easily accessed and read on a PC
  • Modified thermistor circuit layout to allow for easy modification & smaller overall footprint
  • Decreased overall size of board

Potential Additions:

  • Support for onboard battery (either 1S or 2S). This would require a power path management IC
  • Potentially turn telem PCB into a TX module and develop an RX PCB to allow live wireless data logging
MCUSTM32F373CCT
ProtocolsUSB, I2C, SPI, SWD
SensorsLSM6DSRXTR Accelerometer, BMP585 Pressure Sensors
2x Linearized RL0503-5820-97-MS Thermistors
GPSu-blox MAX-M10S (Integrated LNA & SAW)
Abracon APAMP-116 Antenna

249g-Class Mini Drone Flight Controller

Active build - Finalizing Schematic
PersonalPersonal

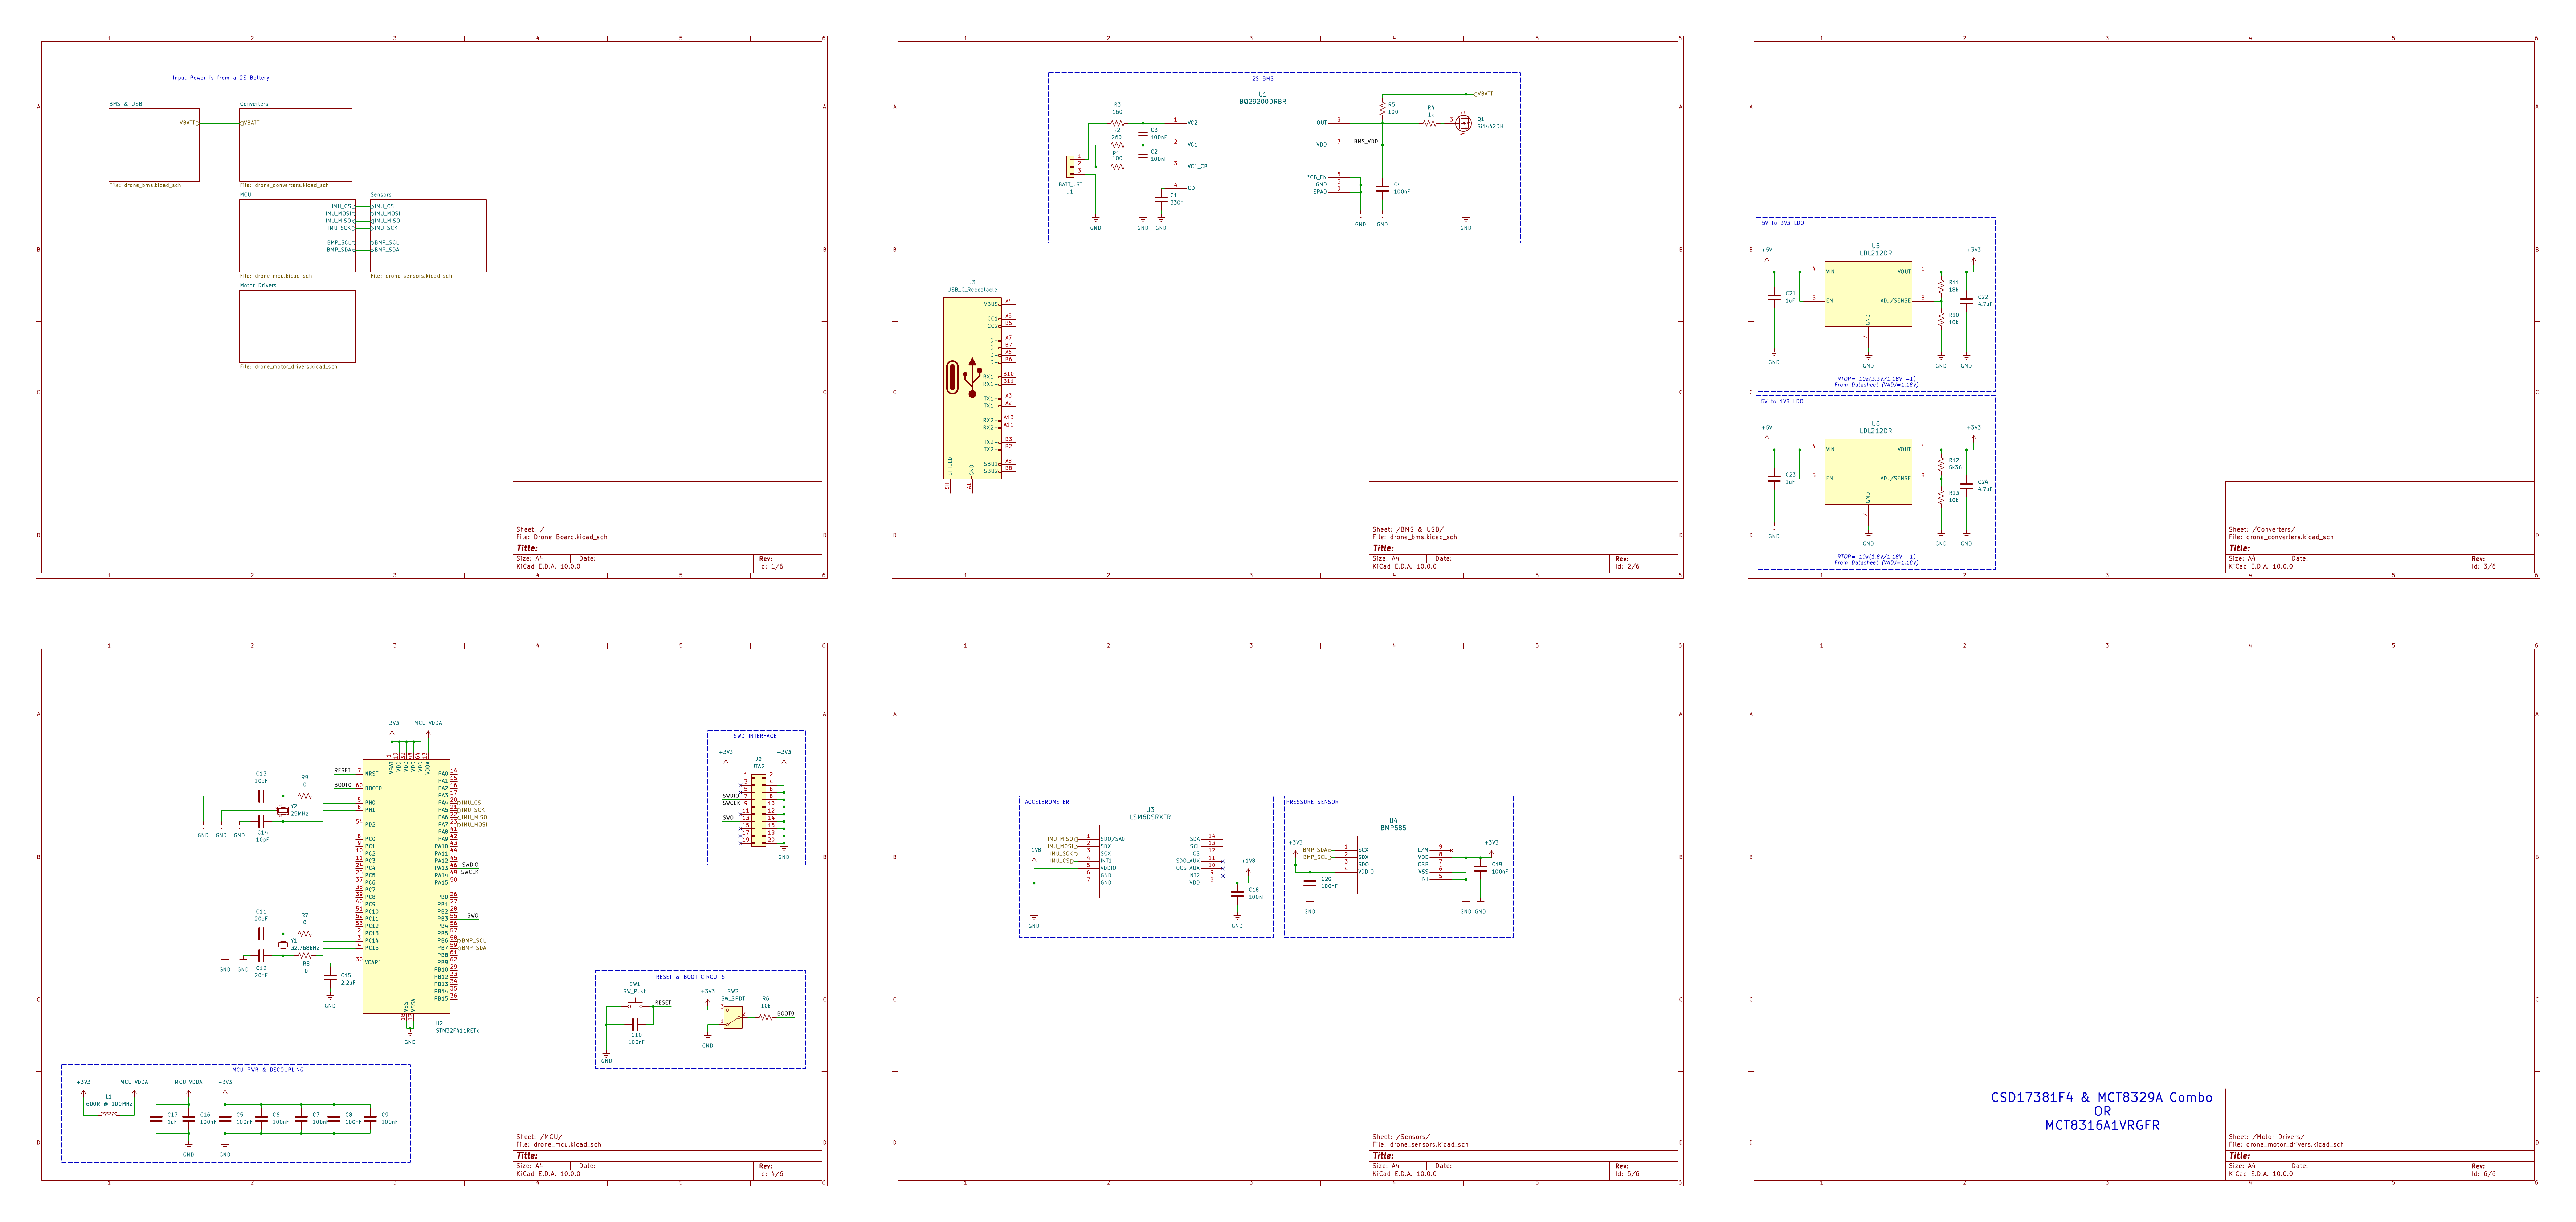
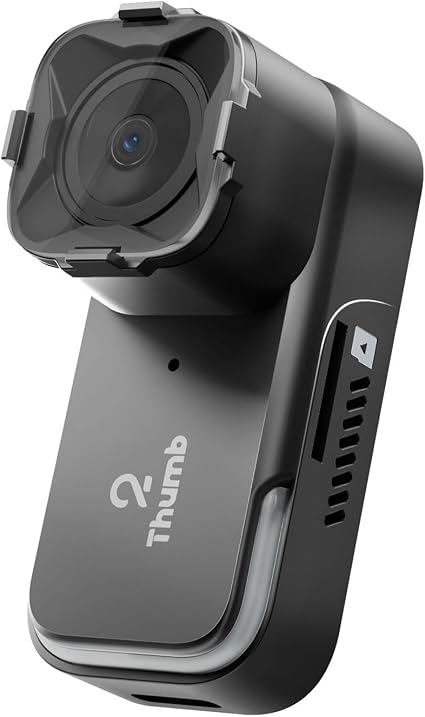
Custom flight controller PCB built for a 249g drone. The drone is intended to be used while hiking to capture images. The chosen camera is a RunCam Thumb 2. Board will be powered from a 2S battery, and will power and control four 10000KV motors.

  • Controls four onboard motors using TI MCF8316A drivers over UART
  • Controlling RunCam Thumb V2 Action Camera over UART
  • Onboard accelerometer and pressure for positional data, using SPI and I2C, respectively
  • Onboard BMS to protect 2S battery
  • Buck converters to convert battery voltage to 5V & 3V3
  • LDO to convert 5V to 1v8 to power pressure sensor
  • SWD header to program and debug MCU using STM NUCLEO-F446RE Dev Board

Coming Soon:

  • Adding RC receiver
  • Potentially switching LDO for 1V8 stage to buck
  • Adding charge controller to charge 2S battery over USB-C
MCUSTM32F411
ProtocolsUSB, I2C, SPI, SWD
Motor drivers4× TI MCT8316A1VRGFR
Motors4× Happymodel RS1102 KV10000
Battery2S1P 4000mAh 21700

FSAE Tractive System

Active build
Formula MUNFormula MUN

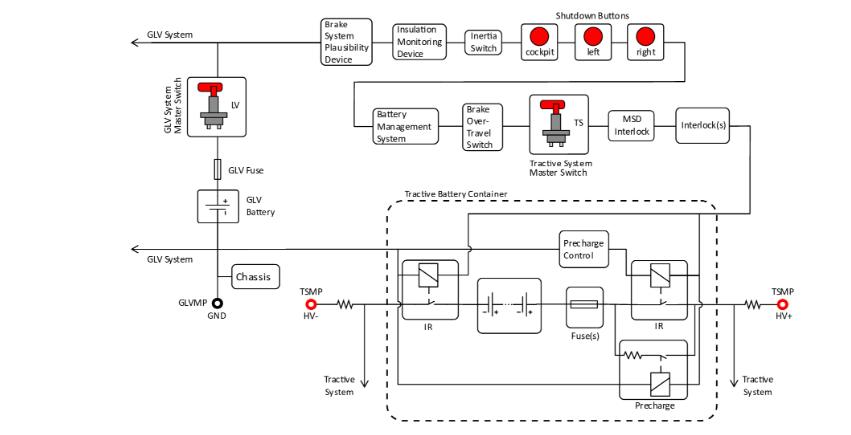
250V Drivetrain and shutoff circuit for a full size FSAE EV

  • Utilizing prebuilt 1S6P Molicel 35A modules to reduce labour needed for assembly
  • Using 250V nominal to reduce cost for first year car, also reducing battery size
  • Integrating Orion O2 BMS for 250V, 6 module pack
  • Reduced overall motor + inverter cost from 14k CAD to 4000 CAD by purchasing older inverter & forum post for Emrax purchasing
  • Using Cascadia Rinehart PM250DZ inverter (leftover from Hyperloop and forgotten so it was free!)
  • Using chain driven differential driveline to reduce drivetrain complexity and allow for easy servicing
  • Developing HV safety and work policies to ensure maximal safety for members
Top Speed100 km/h (62 mph)
0-60km/h4 seconds
Voltage250V Battery
MotorEmxrax 228 (LV)

Paradigm 10kW Go-Kart Drivetrain

Complete
Paradigm EngineeringParadigm Engineering

10kW Powertrain for Paradigm 2026 Go Kart.

  • DC Contactor for Physical and Remote E-stop
  • Redundant shutoffs: If auxiliary power or control signals are lost, motor will not have power
  • Using Golden Motor Inverter, with CAN and analog controls
  • Capable of up to 150A, supplied by a 72V 50Ah Molicel pack
Top Speed120km/h (74.5mph)
Battery72V 50Ah Molicel
Motor10kW Golden Motor Liquid-Cooled BLDC

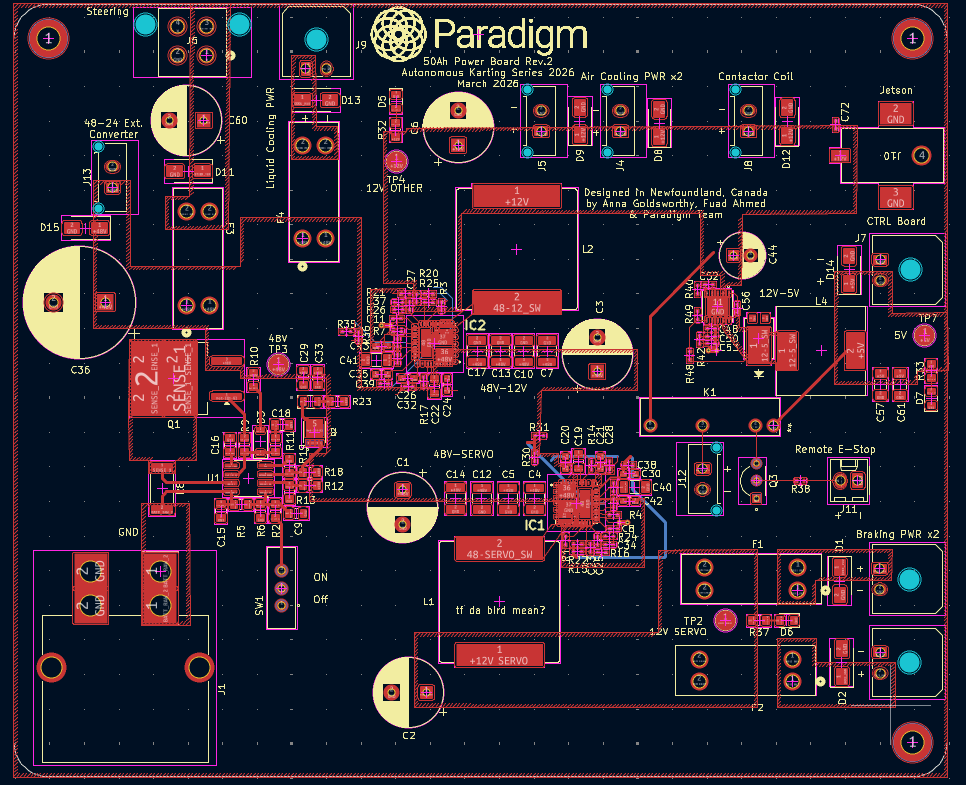
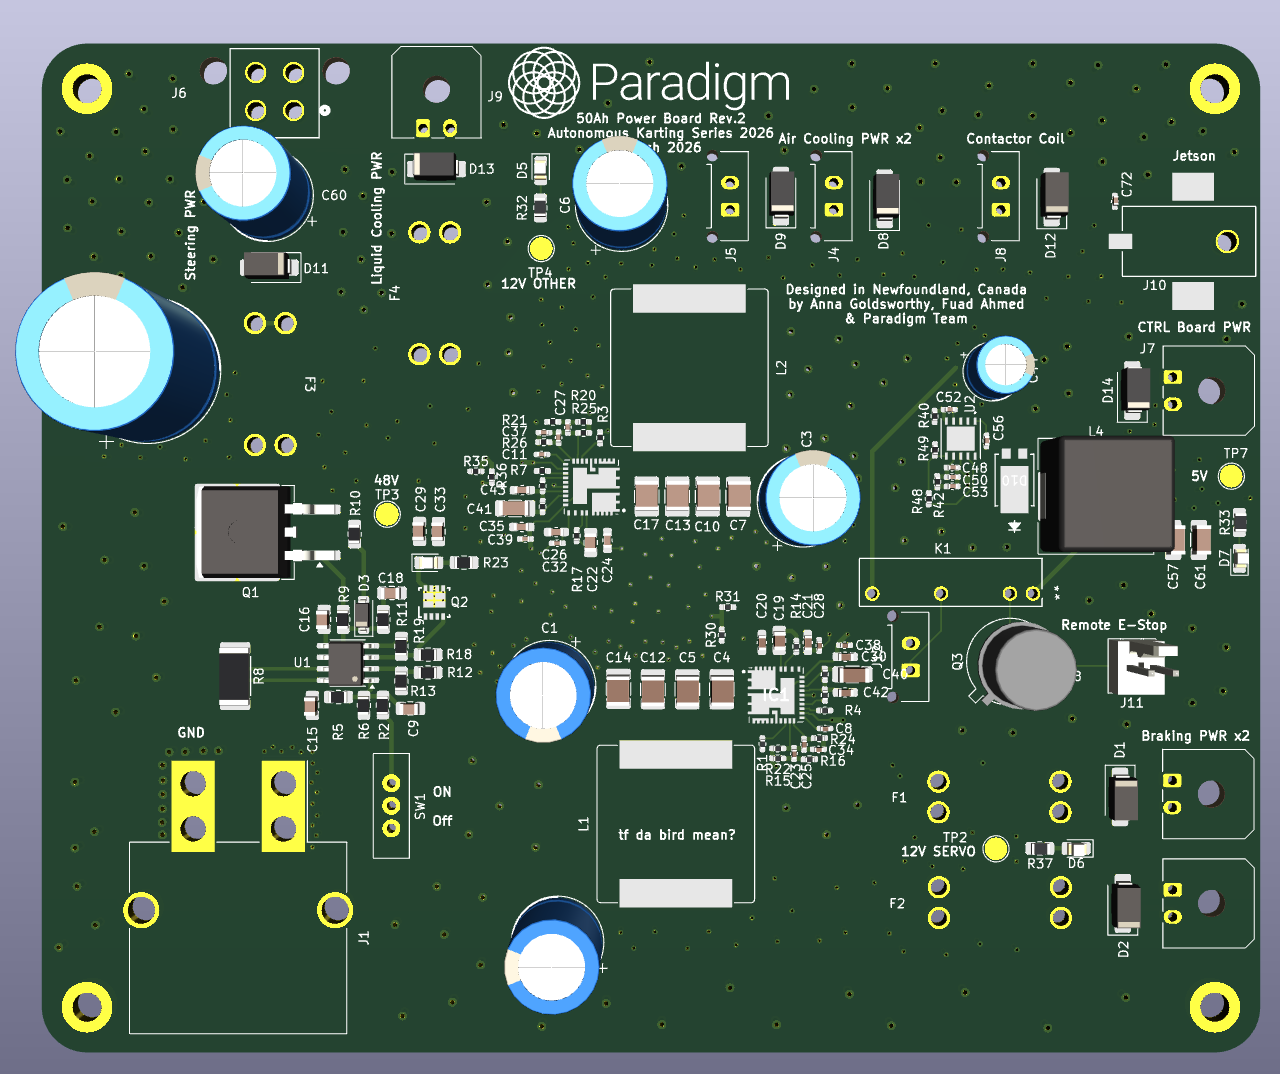
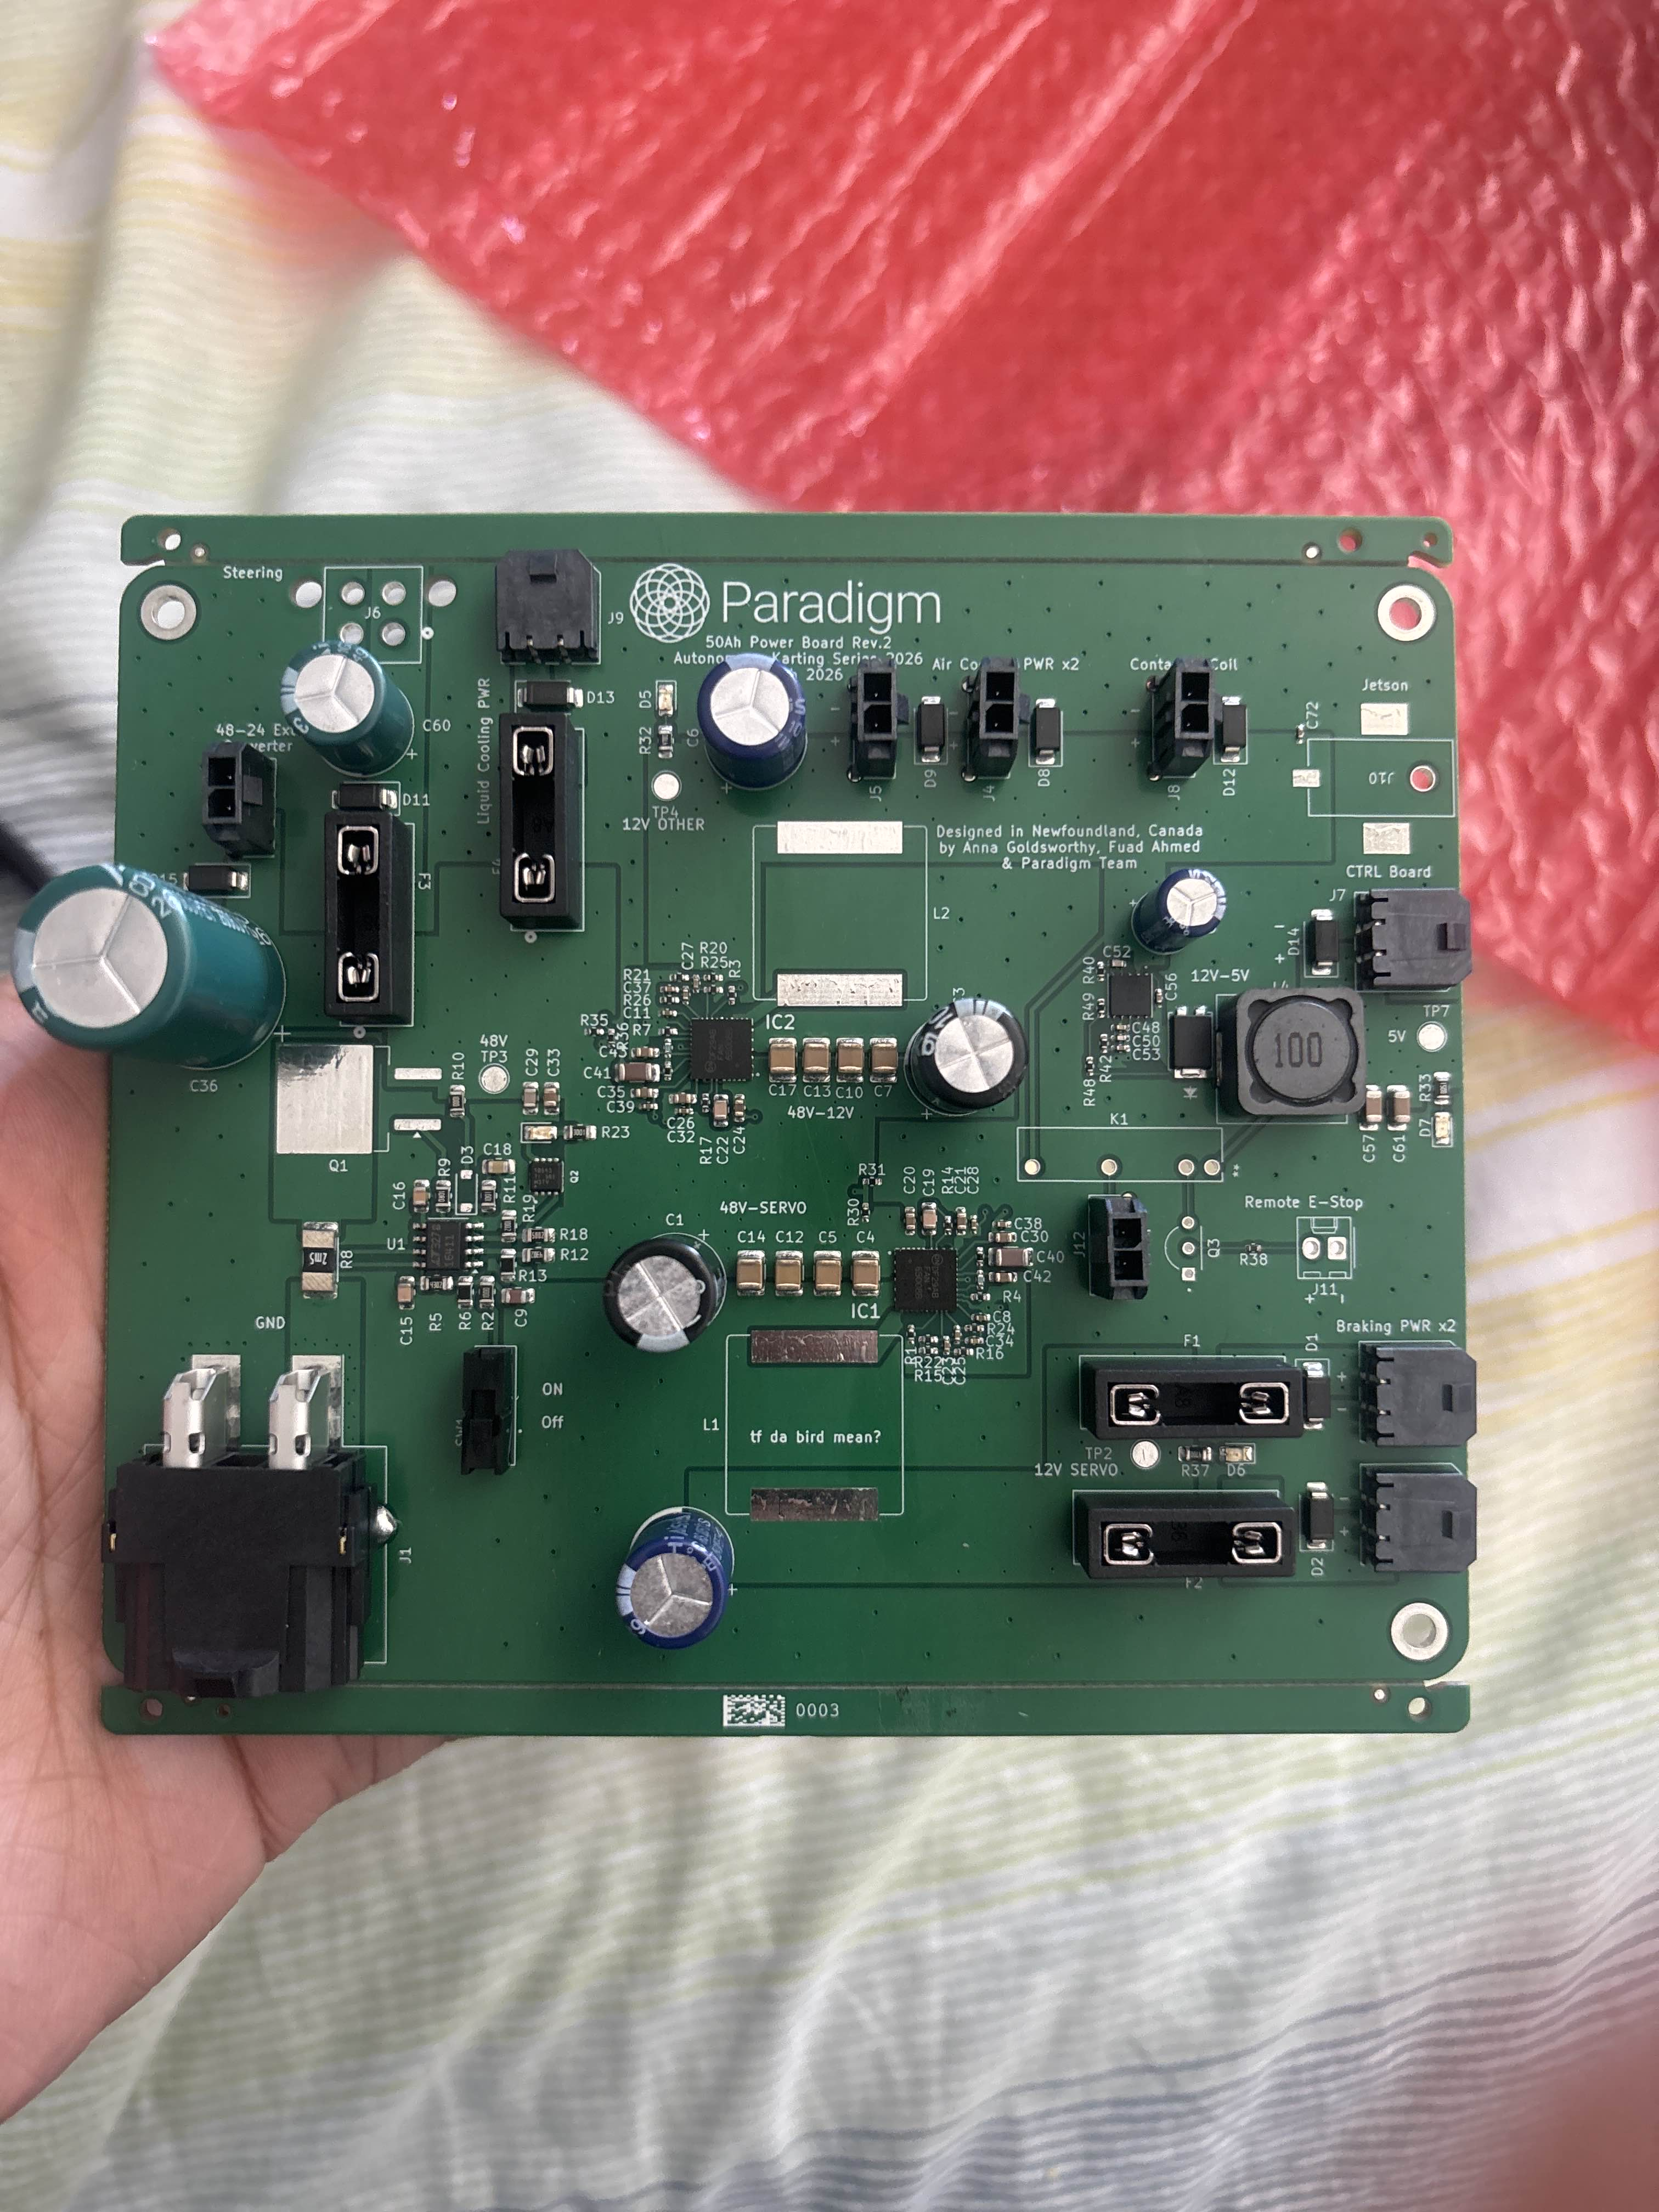
50Ah Power Board

Complete
Paradigm EngineeringParadigm Engineering

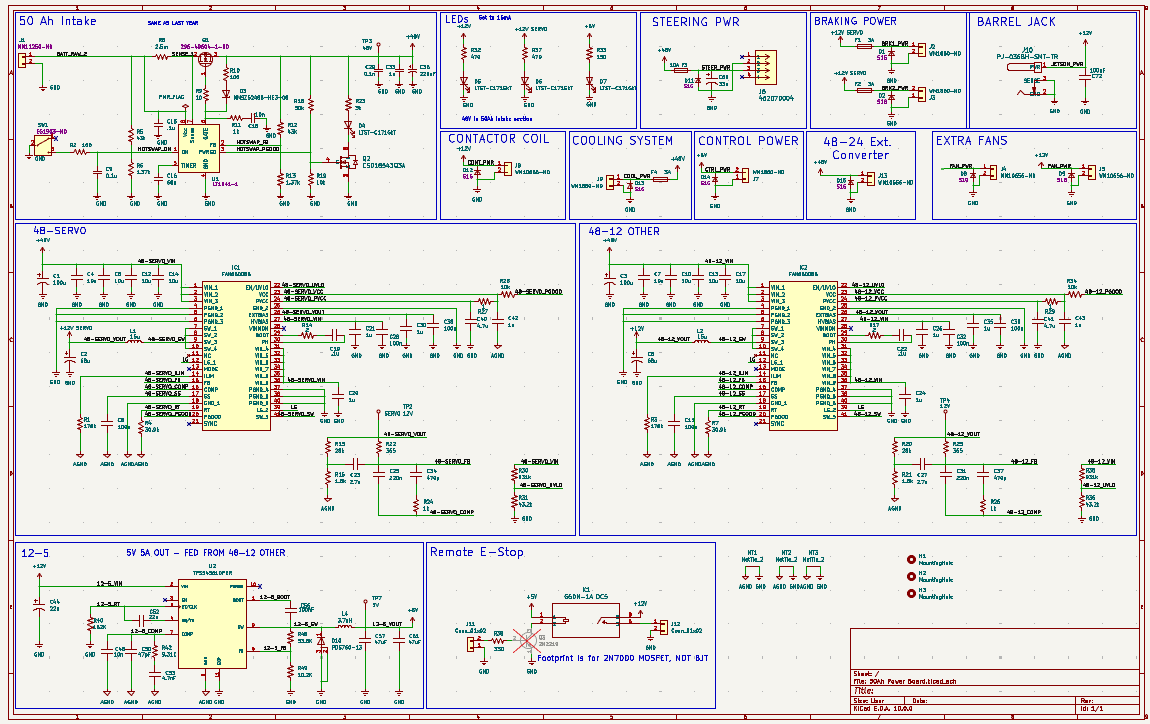
Power Distribution PCB for Paradigm 2026 Go Kart.

  • Supplied using Aegis 48V LiNMC Battery
  • Powers onboard 48V motor for steering and 12V servos for brakiung
  • 2 seperate 48V-12V Onsemi FAN6500B Buck Converters, capable of up to 10A output
  • TI TPS54561DPRR Buck converter for 12V to 5V conversion
  • Remote E-Stop to cut drivetrain relays when triggered by RC controller
  • Battery Intake protections using Analog Devices LT1641-1 hotswap IC
Buck ControllerOnsemi FAN6500B
Power Levels48V, 12V, 5V, 3V3
Layers4

Auxiliary Control Board

Complete
Paradigm EngineeringParadigm Engineering

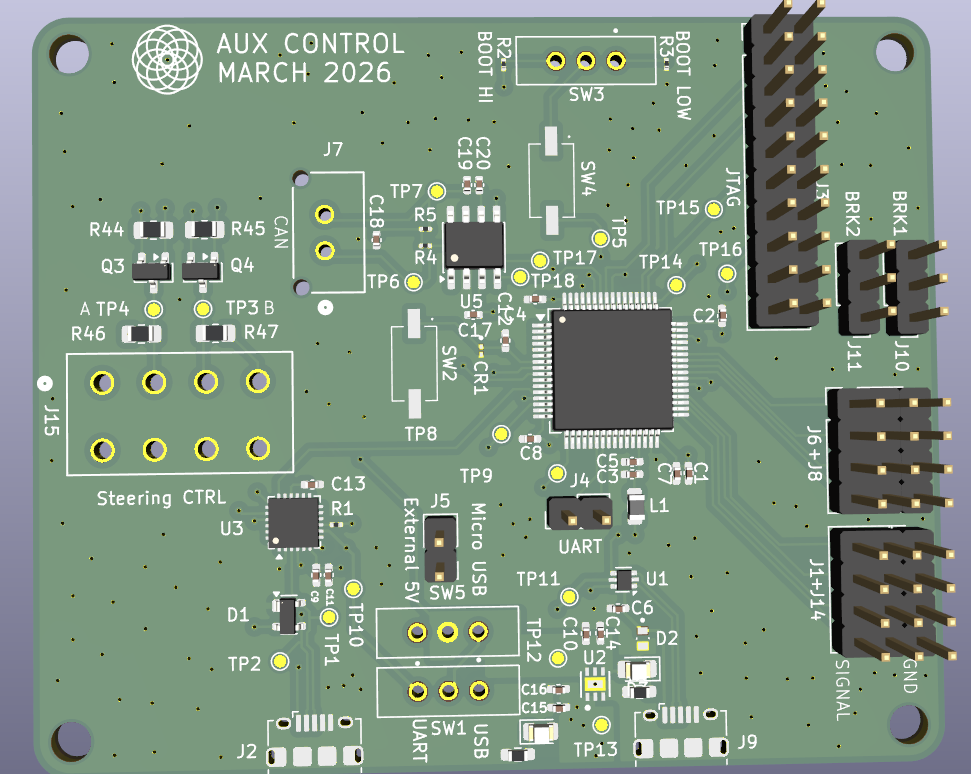
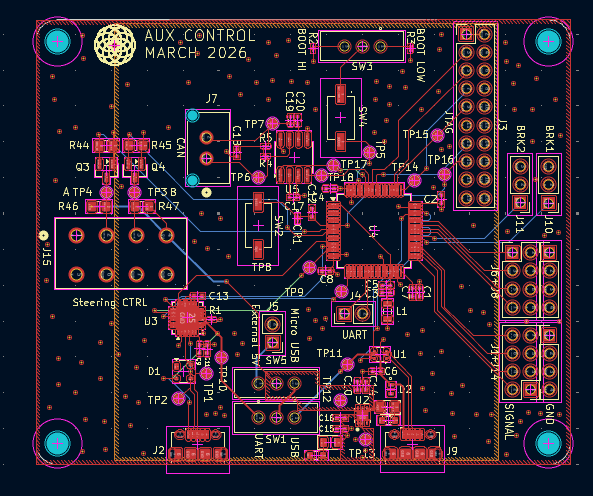
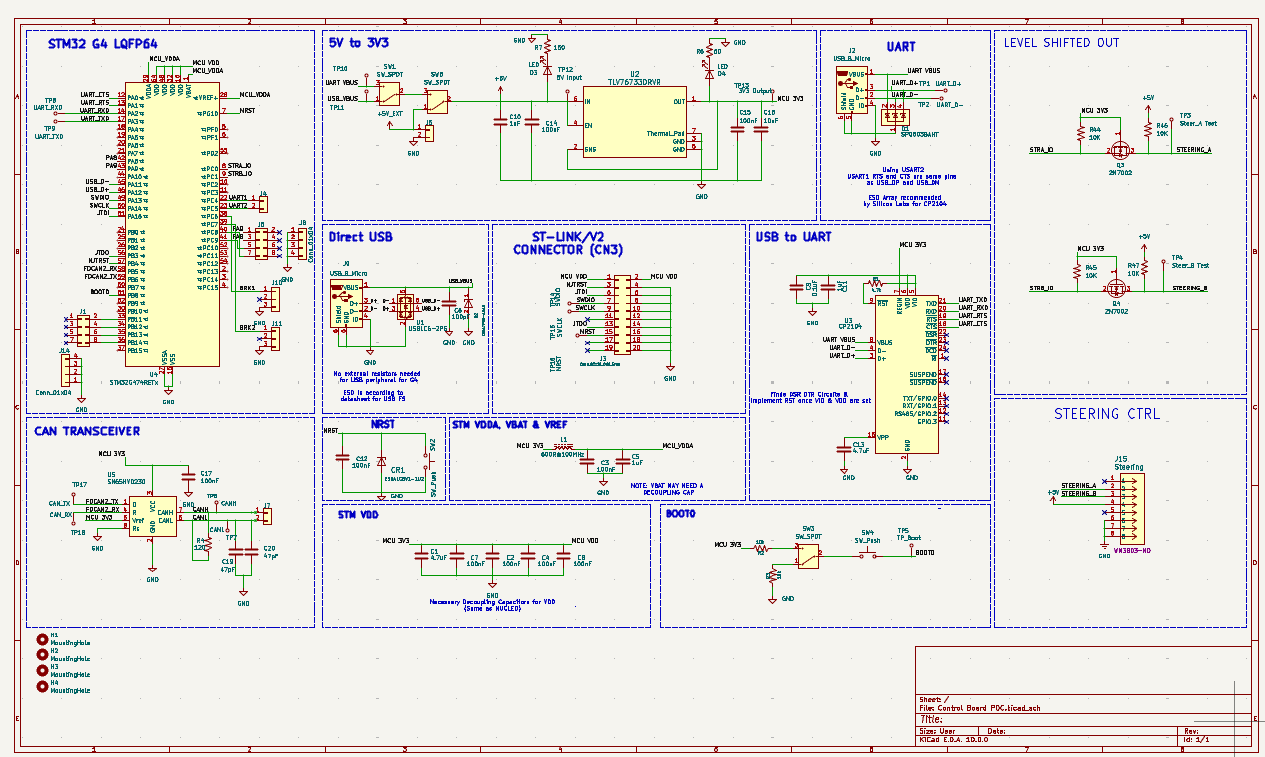
Final Control PCB for Paradigm AKS 2026. Based on STM32 POC board, with addition of a CAN transceiver and additional pin breakouts.

  • Uses TI SN65HVD230 CAN transceiver to control drive motor
  • Uses PWM to control onboard braking serovs & steering motor
  • Uses Si Labs CP2104 USB to UART bridge to receive UART commands from onboard computer
  • TI TLV76733DRVR LDO to convert 5V input to 3V3
  • Micro USB headers with ESD protection for USB & UART interfaces
MicroprocessorsSTM32G474RET6
InterfacesJTAG, UART, USB, CAN
Power Levels5V & 3V3 (Using STMLD3985M33R_SOT23)
Layers4

STM32 POC Board

Complete
Paradigm EngineeringParadigm Engineering

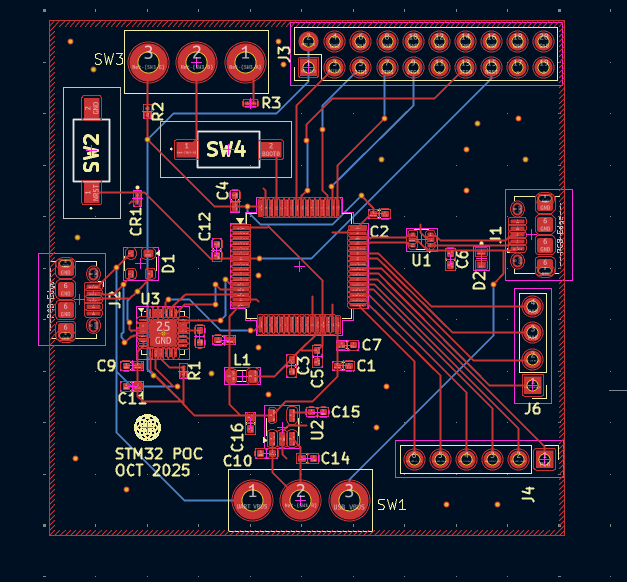
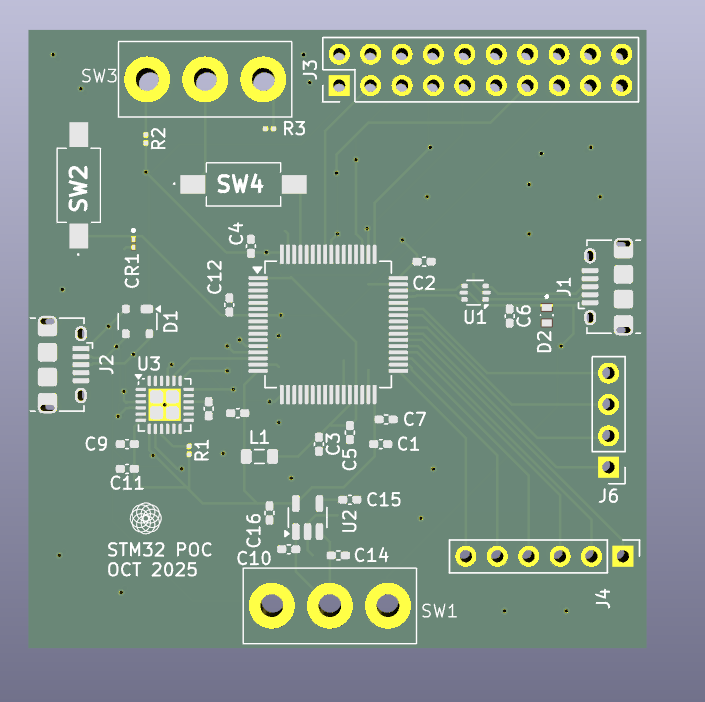
Proof of Concept STM32 Board for testing and development of AKS 2026 Controls. Served as validation of hardware design and firmware integration of the STM platform and STM32G474.

  • Uses Si Labs CP2104 USB to UART bridge to receive UART commands from onboard computer
  • PWM Capable GPIO pins broken out for firmware development and testing
  • Micro USB headers with ESD protection for USB & UART interfaces
  • 20 pin JTAG header to allow debug using ST-LINK V2-ISOL
MicroprocessorsSTM32G474RET6
InterfacesJTAG, UART, USB
Power Levels5V & 3V3 (Using STMLD3985M33R_SOT23)
Layers4

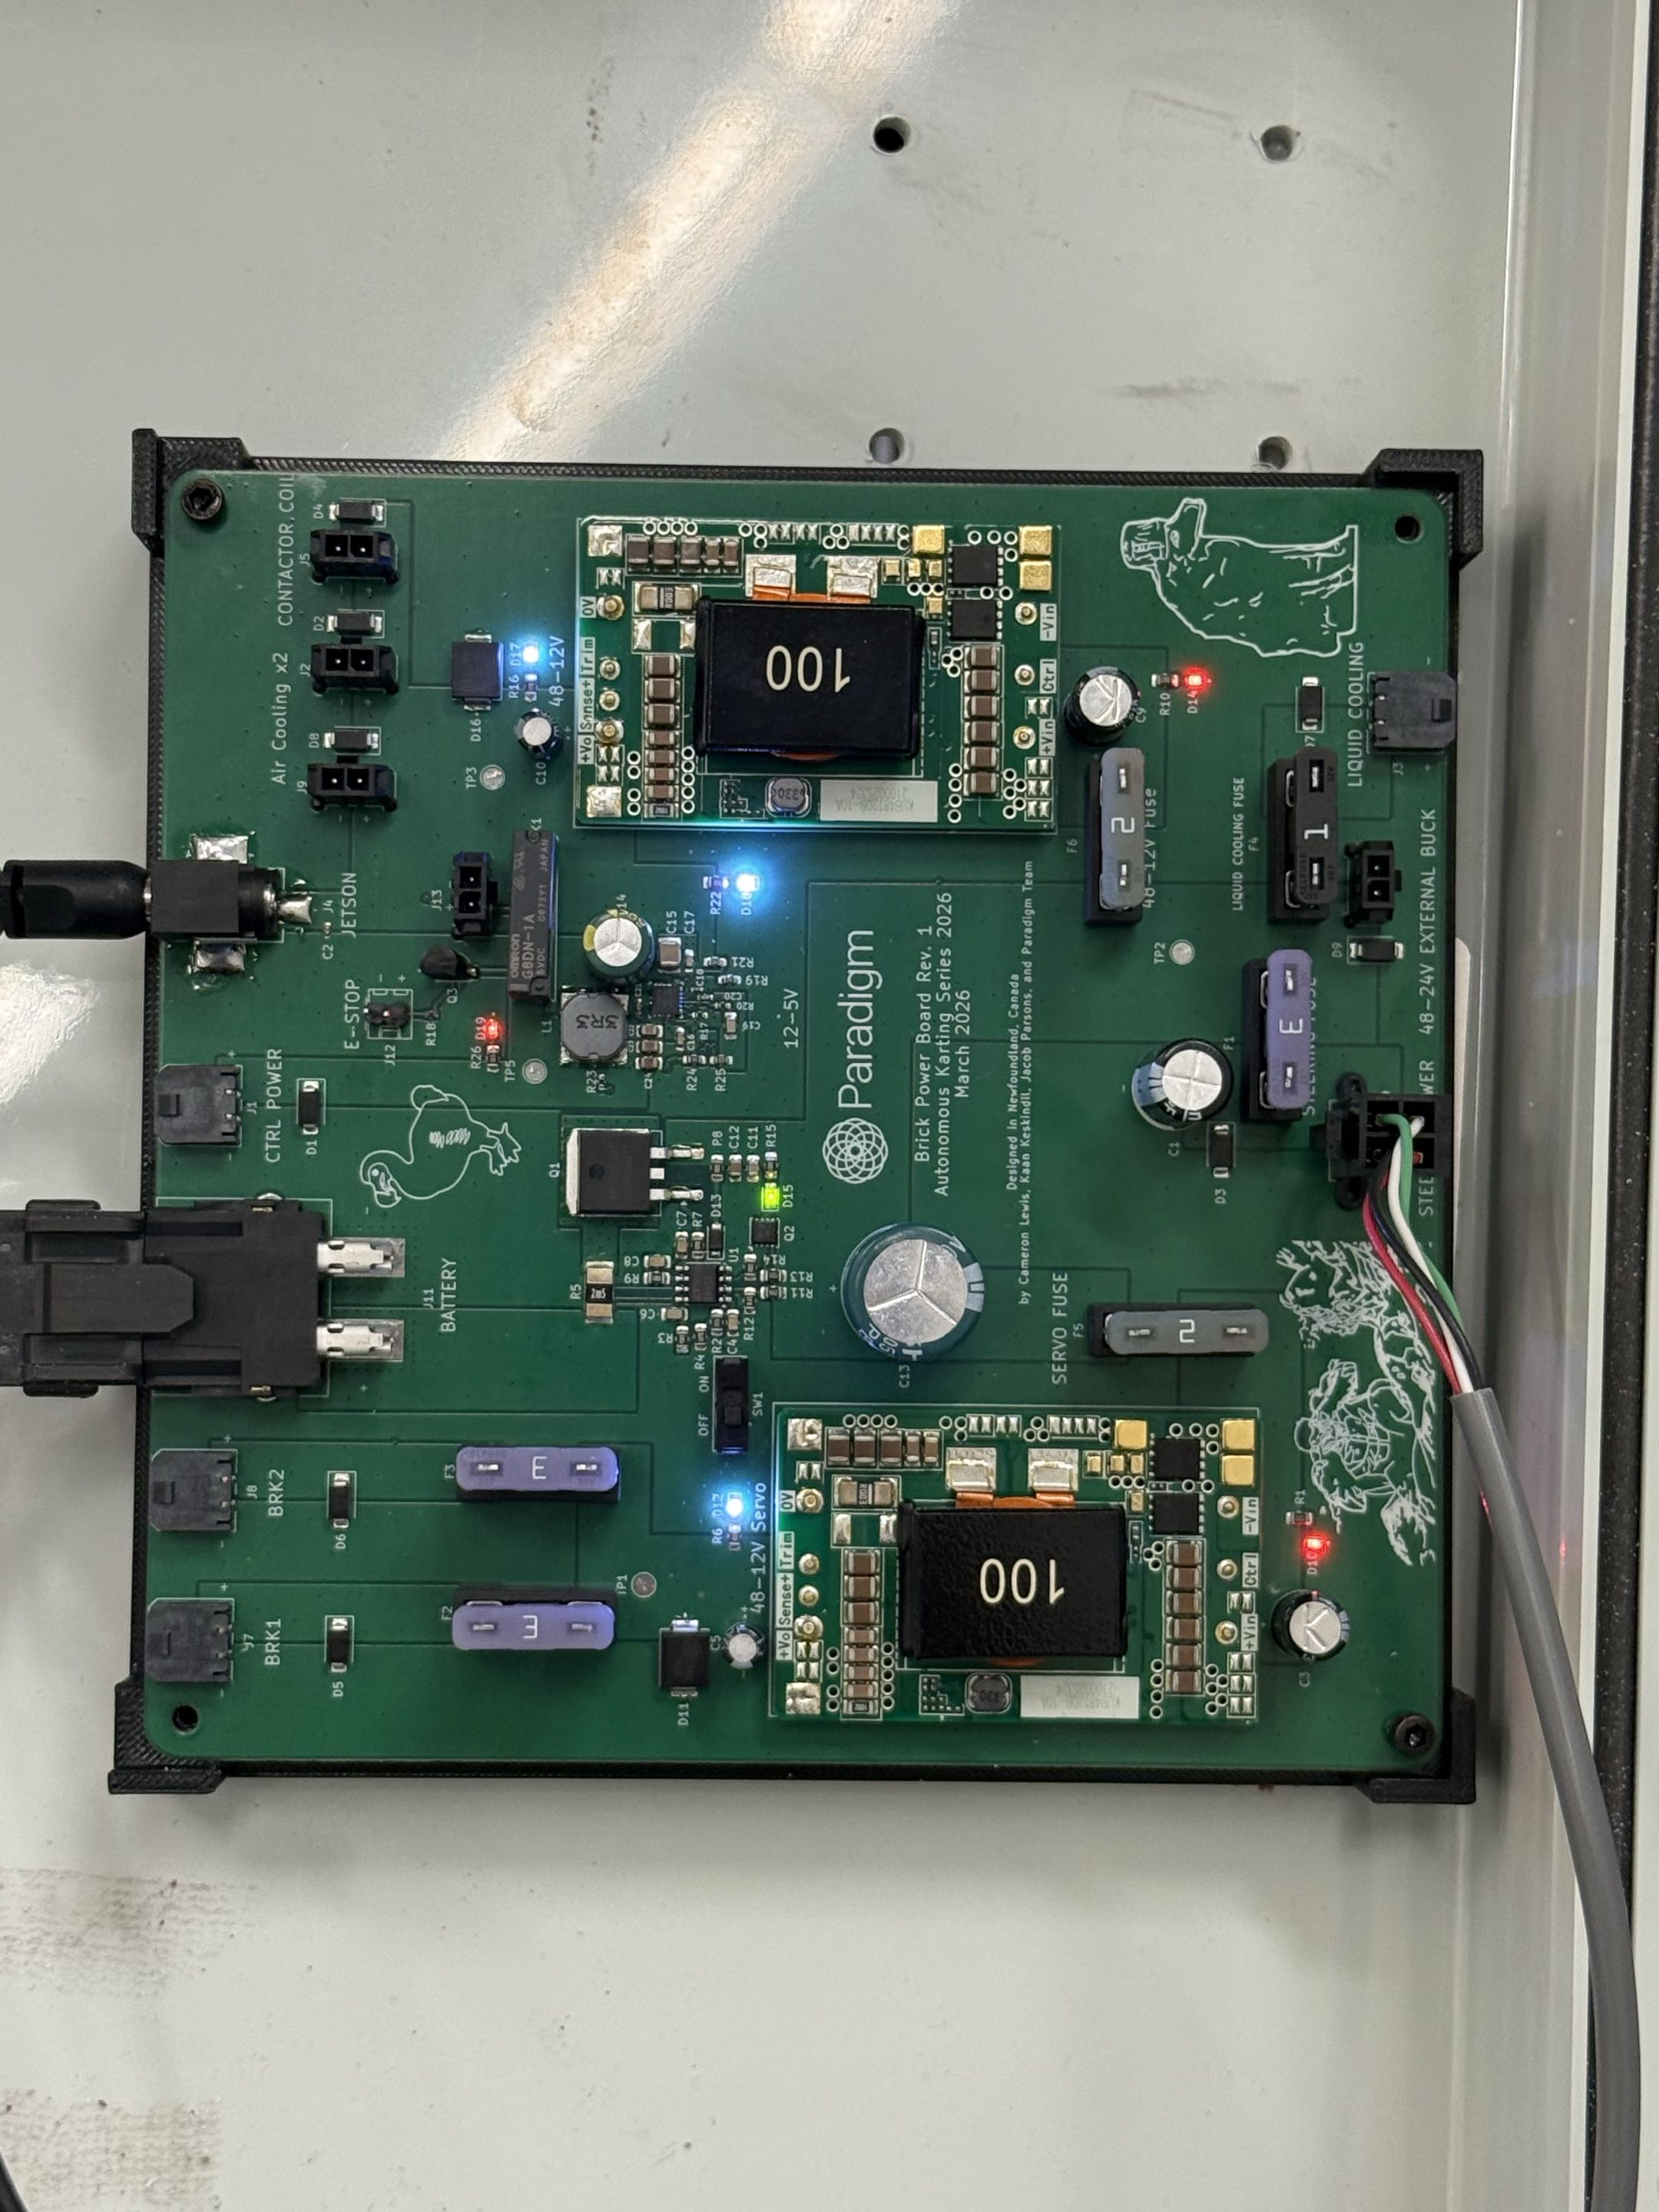
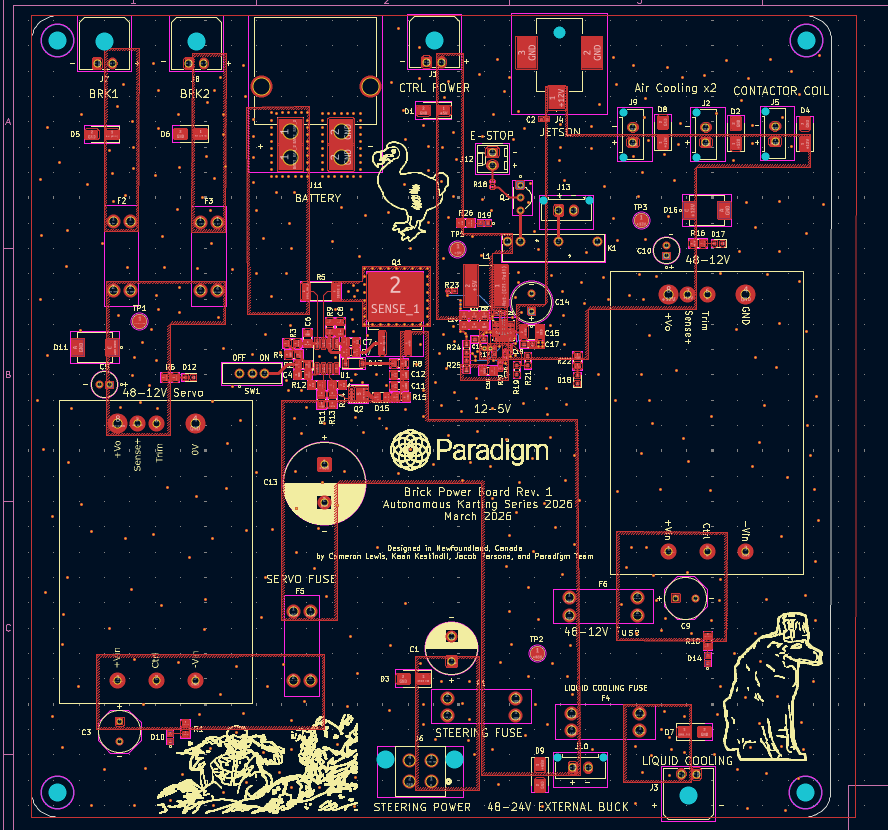
50Ah Backup "Brick Buck" Board

Complete
Paradigm EngineeringParadigm Engineering

Backup System for the 50Ah Board using premade buck converter modules

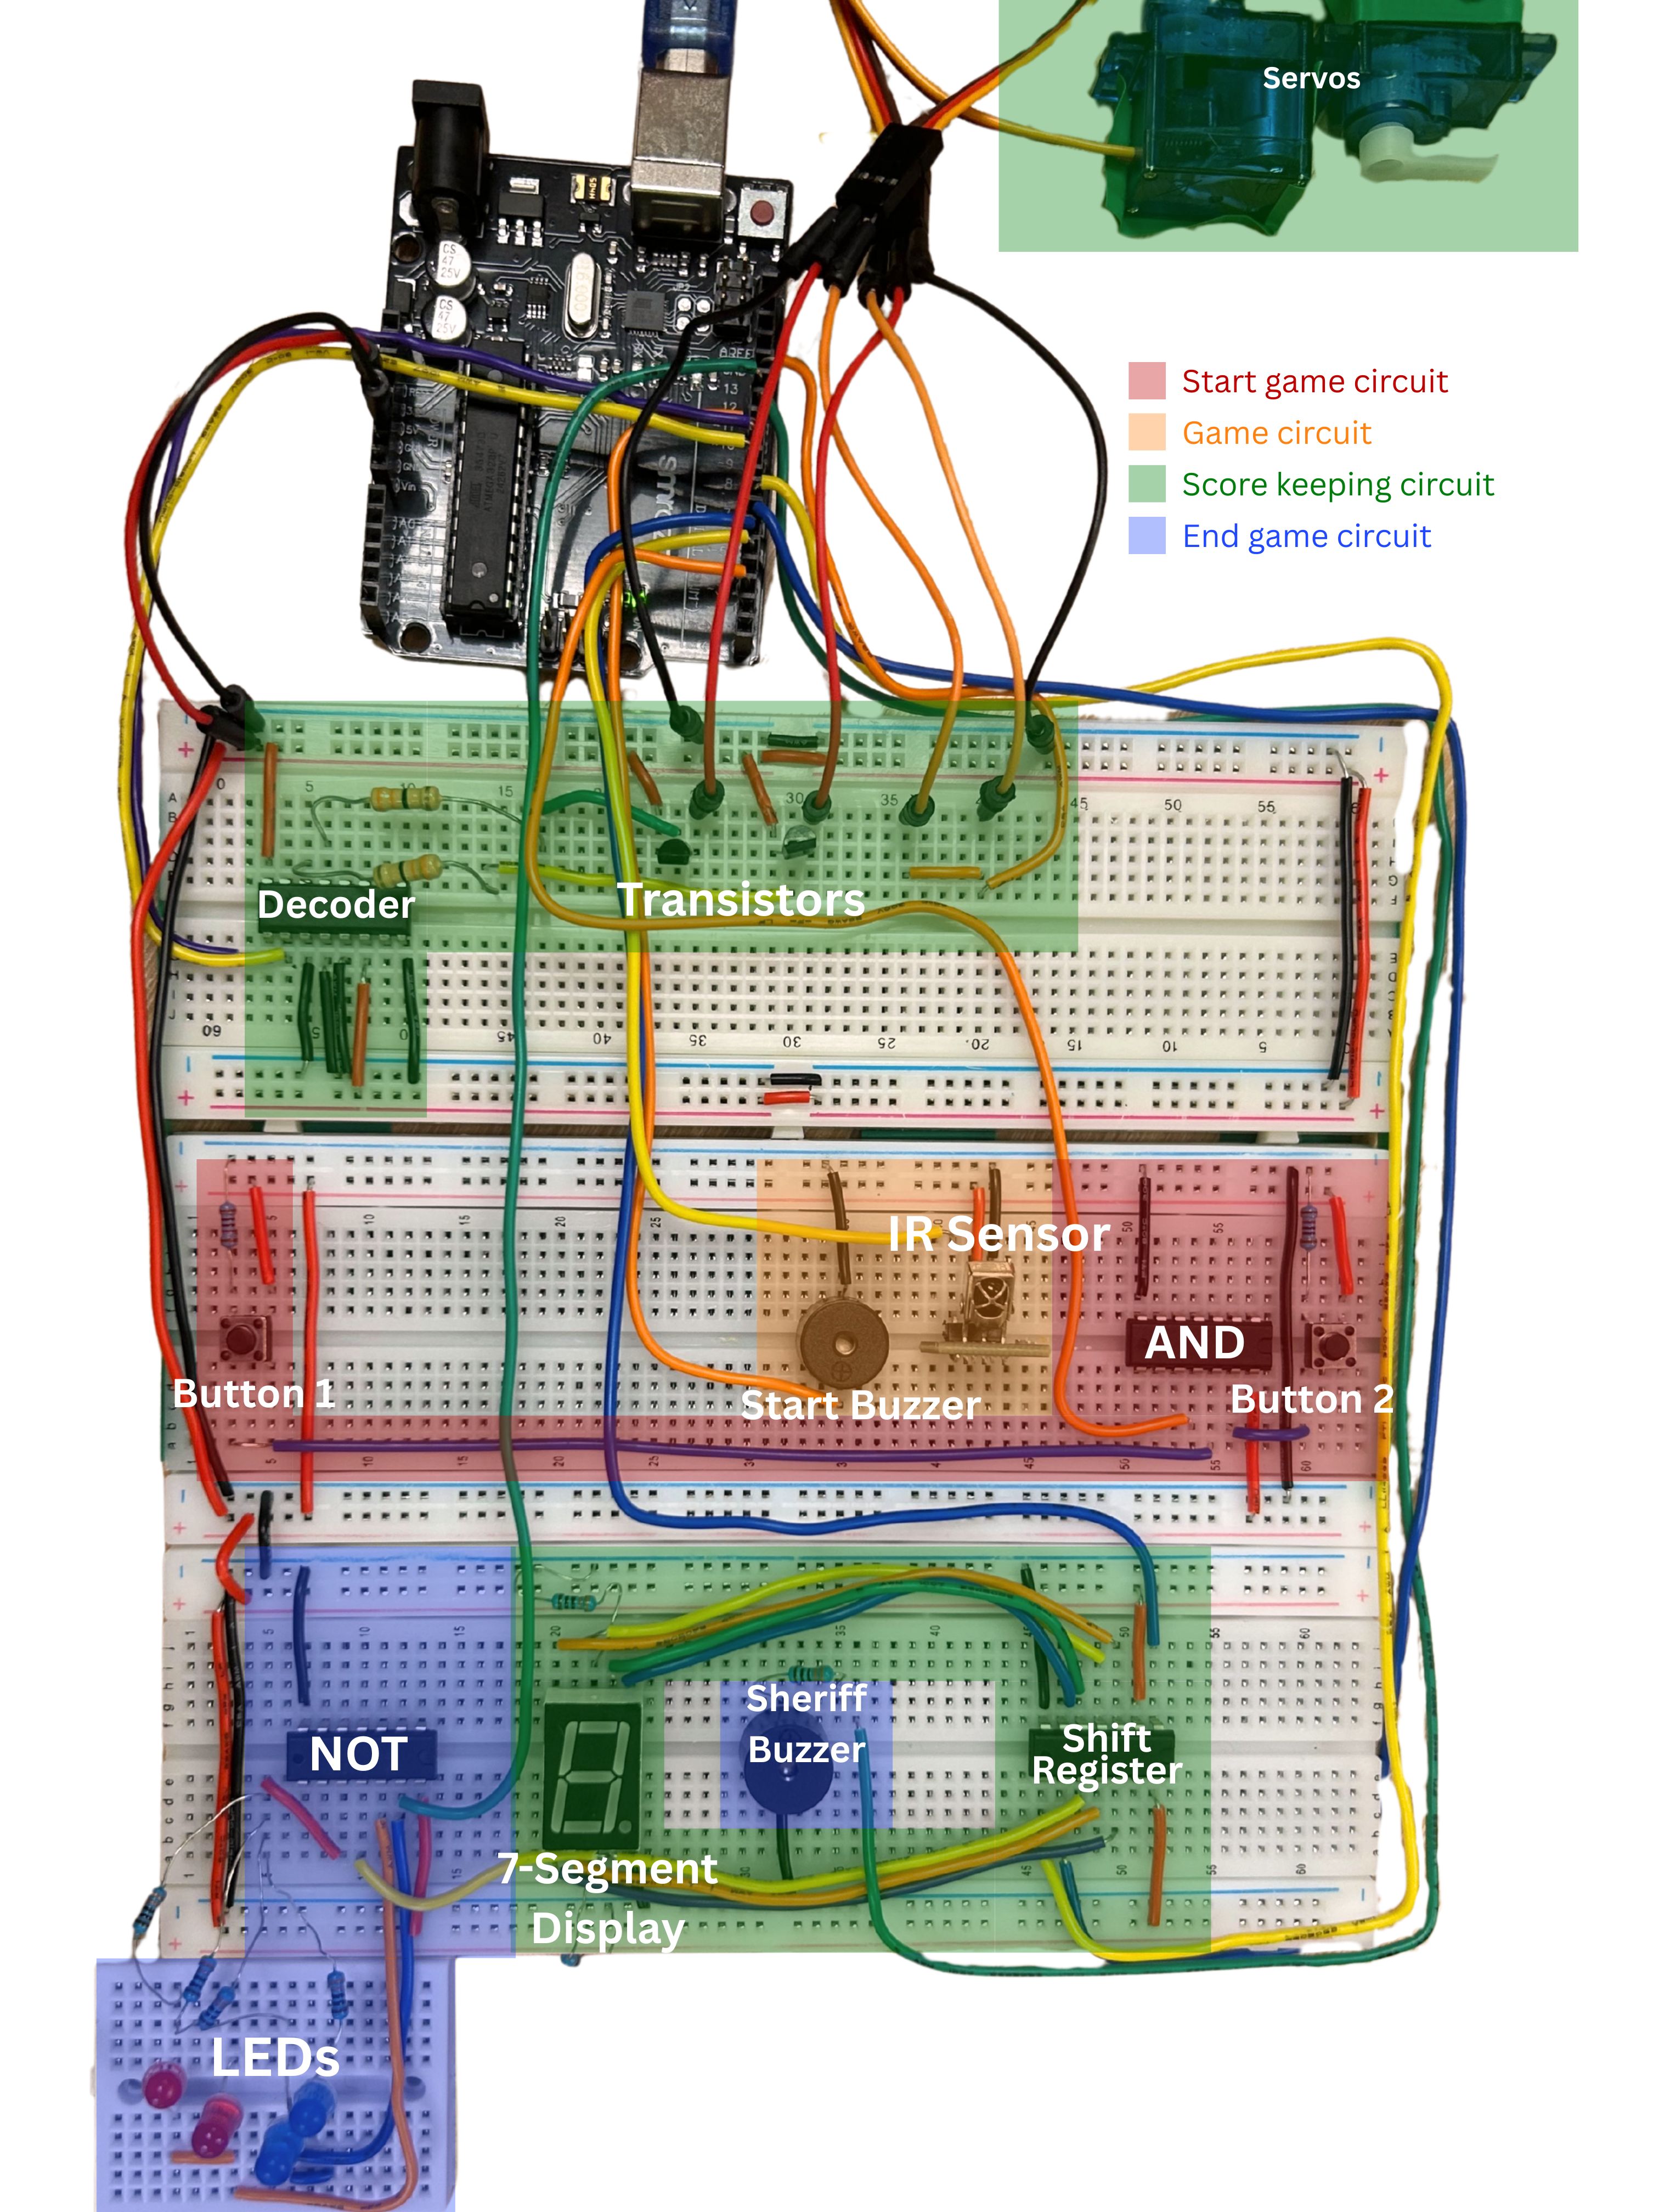
DigiDuel

Complete

Final Project for ECE4510: Digital Logic and Microprocessors